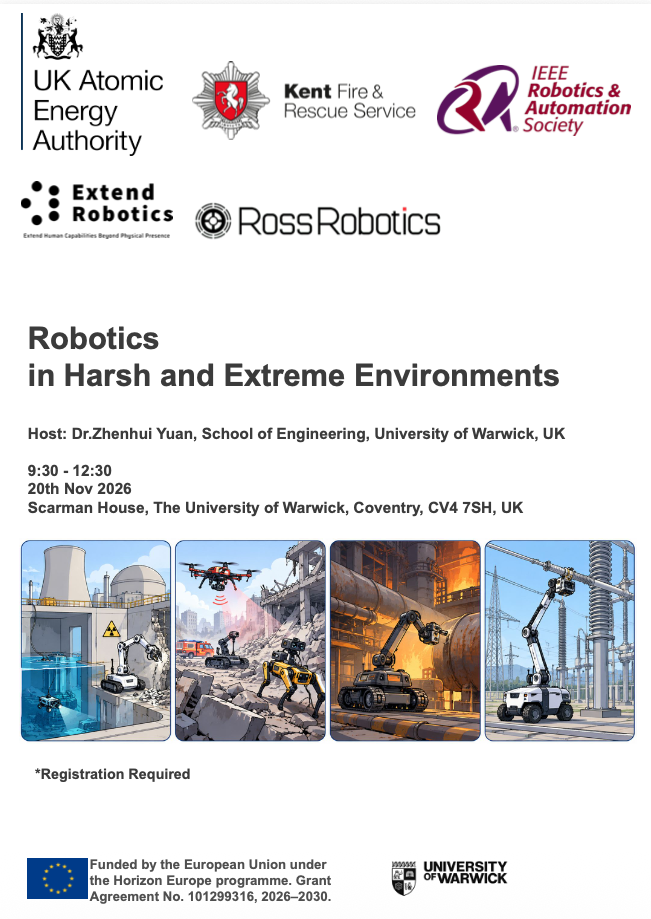
About
Toward a smart robotic team in most challenging environments.
Robots hold great potential to support humans in extreme environments—such as post-disaster
zones—where conditions are hazardous, unpredictable, and often lack reliable connectivity.
Their capacity to operate in dangerous or inaccessible areas makes them crucial for search
and rescue, damage assessment, and emergency response. Yet, conventional robotic systems
often struggle in such contexts due to limited adaptability, fragile autonomy, and
insufficient coordination. Challenges like degraded sensor inputs, dynamic unstructured
terrains, GPS-denied environments, and constrained communications further hinder their
effectiveness. While embodied AI has significantly enhanced the perception and action
capabilities of individual robots, its focus has largely remained on single-agent systems.
Achieving efficient multi-robot collaboration under uncertain, real-time, and
bandwidth-limited conditions remains a major research frontier. The DIRECT project
tackles these challenges by developing an innovative distributed machine learning framework
that enables a fleet of robots to collaboratively perceive, reason, plan, and act in extreme
environments.
Objectives
O1
Distributed perception, reasoning, planning and action pipeline
Develop a four-stage pipeline (perception, reasoning, planning and action) that
enables distributed task execution across a robot swarm in disaster zones.
O2
Resilient federated learning
Design a resilient federated learning model optimized for limited connectivity and
hardware constraints.
O3
6G-powered sensing–computing–communication infrastructure
Develop a 6G-powered integrated sensing–computing–communication infrastructure that
supports collaborative perception, reasoning and co-planning.
O4
Human-in-the-loop collaborative decision-making
Implement human-in-the-loop collaborative decision-making for remote support of
multi-robotic systems.
O5
Validation through simulation and benchmarking
Validate the DIRECT framework through simulation, benchmark model and dataset
development.
Work Packages
WP1
Project Management and Coordination
WP2
Mission Requirements and System Architecture
WP3
Distributed AI Framework for Multi-robots Collaboration
WP4
6G-Enabled Sensing–Computing–Communication Infrastructure for Distributed AI
WP5
Collaborative Human-Robot Interaction Framework
WP6
Framework Integration, Evaluation and Pilot Study
WP7
Communications, Dissemination, Standardization and Exploitation
WP8
Ethics Requirement